Project under development
Touch, in the service of robotics.
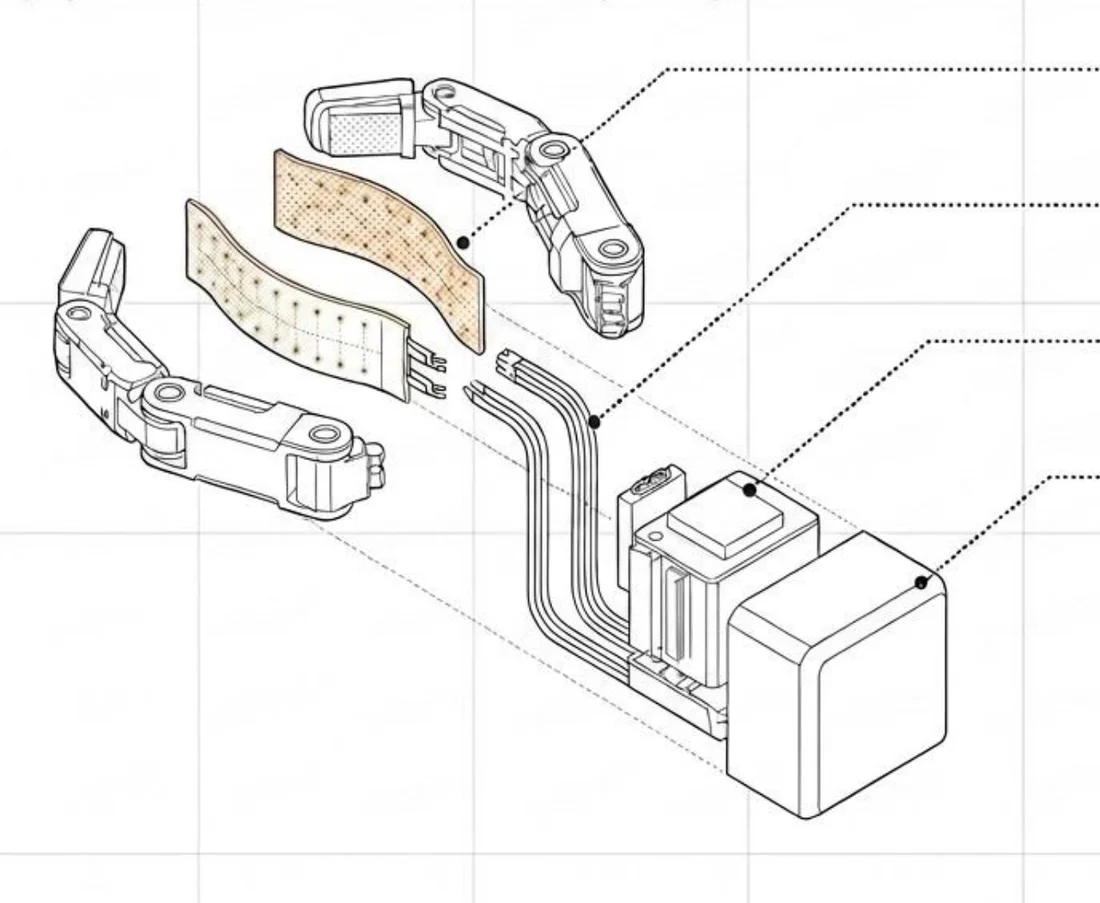
Hyper Tact is developing a robotic gripper with distributed tactile sensors and adaptive grip control, designed to handle delicate and variable objects.
We start from a sensor that has already been tested. The next step is integrating it into the gripper, turning contact information into a grasp that adapts to the object.
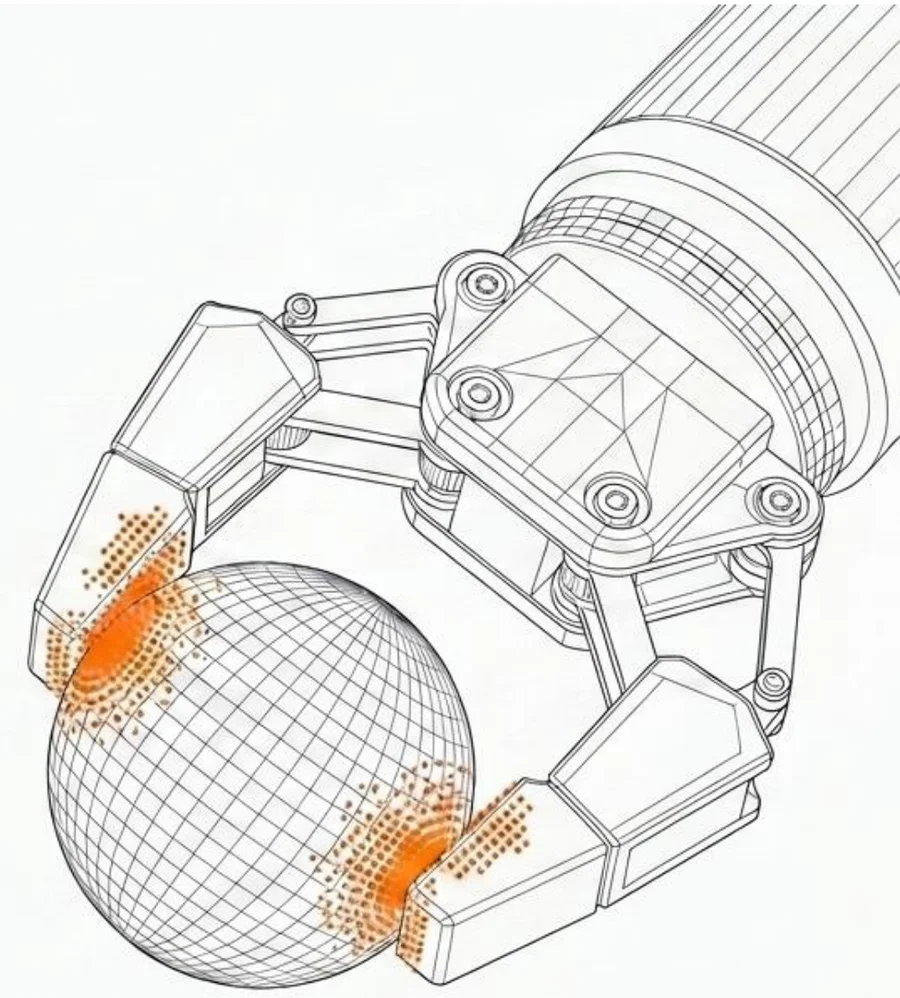
Every object calls for a different grasp.
A soft fruit, a delicate food item, a deformable component: shape and consistency change how they need to be gripped. Too much force can damage them; too little makes handling unstable.
Tactile perception adds information about the contact between gripper and object. Hyper Tact was founded to use that information in grip control, with the aim of making handling gentler and more adaptable.
Bring us your handling challenge.
We are looking for companies and integrators interested in exploring applications of tactile technology. The conversation starts from your process.